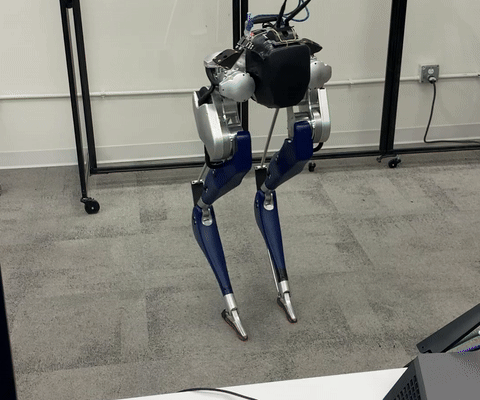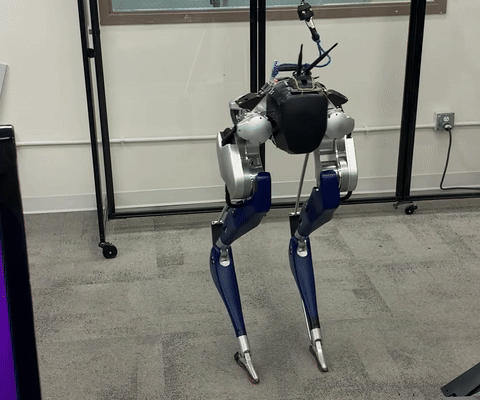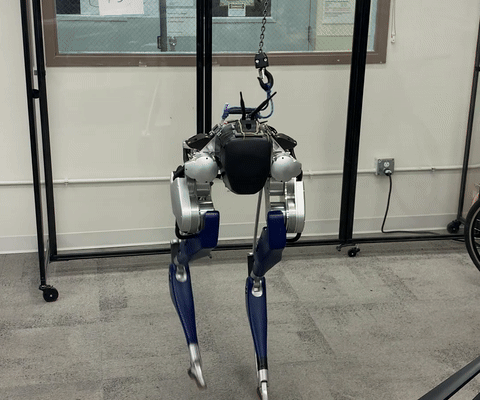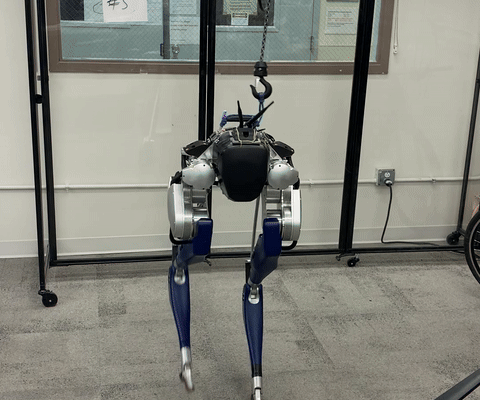
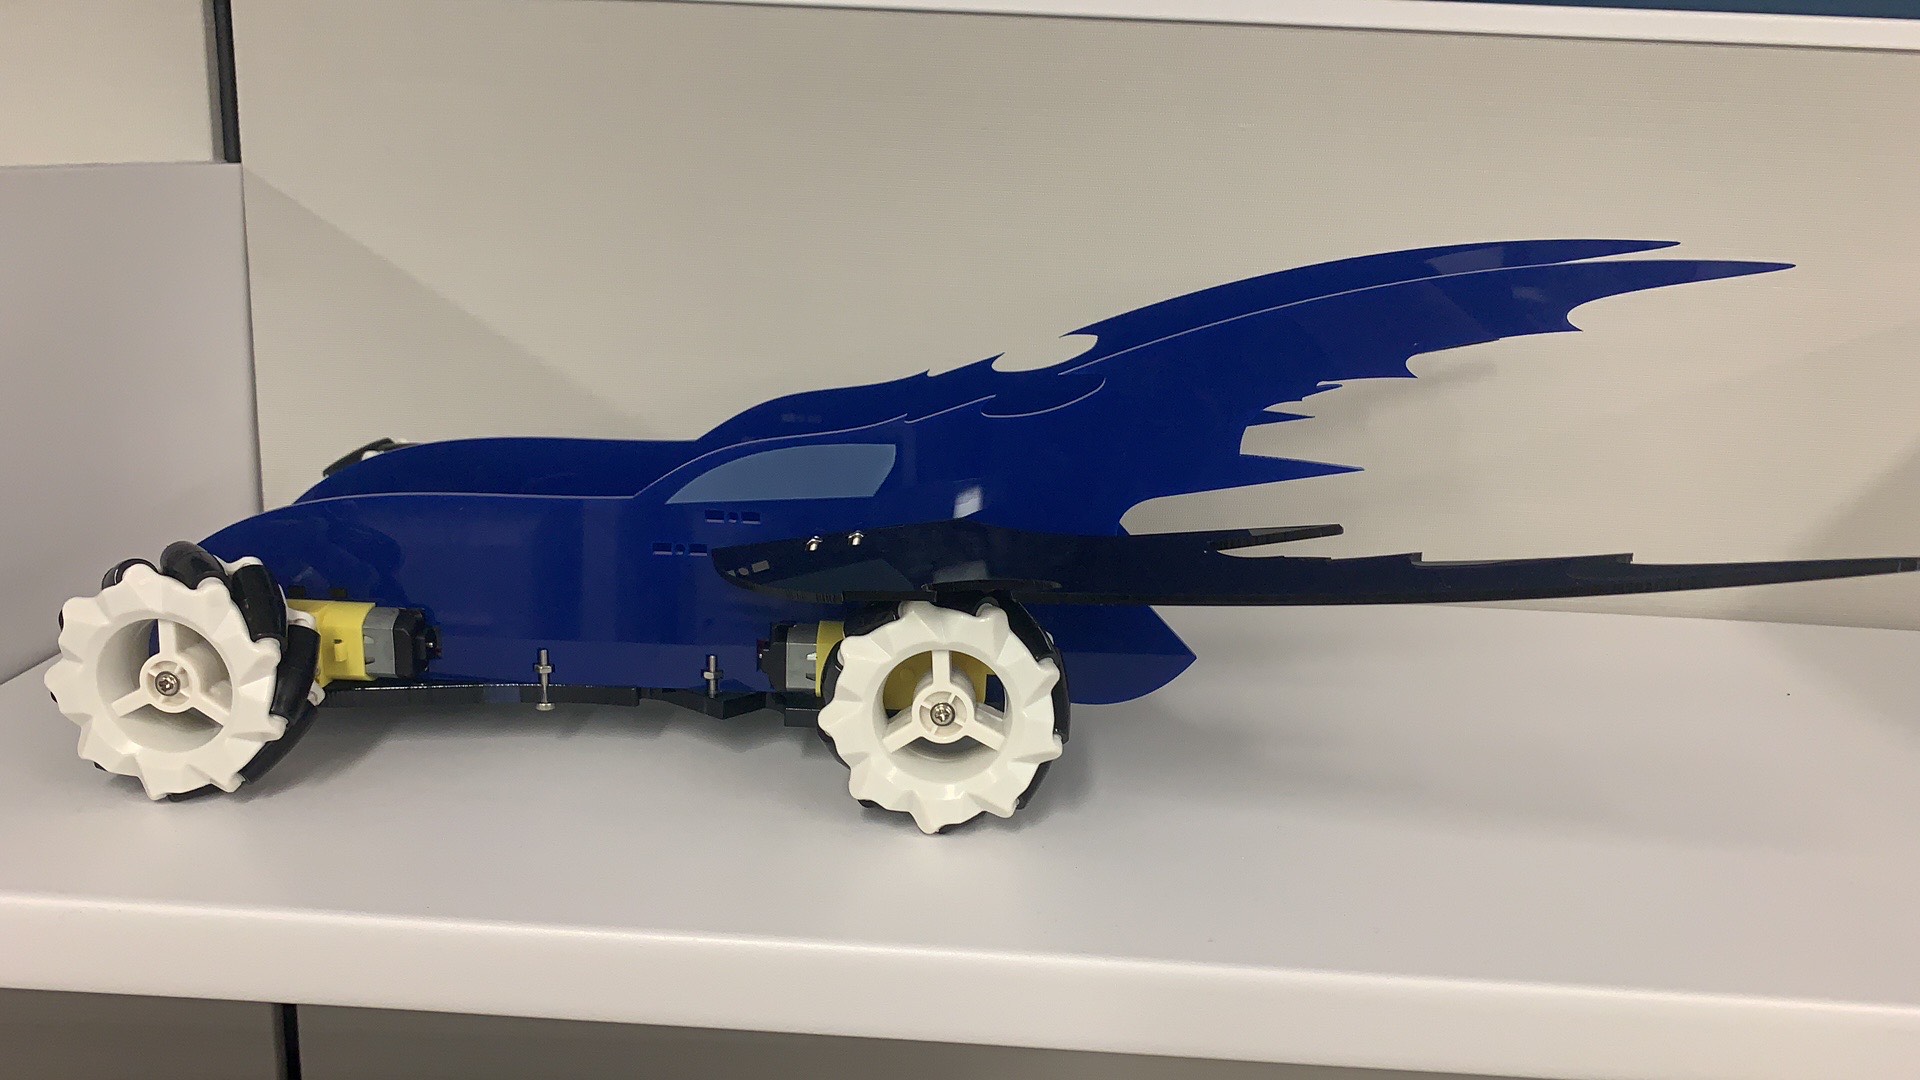
work Sim-to-Real Control of the Cassie Bipedal Robot Developed sim-to-real control strategies for the Cassie bipedal robot, focusing on trajectory optimization, feedback control, system identification and state estimation. Motion Planning, Path Search, and Visual-Inertial Odometry for UAVs End-to-end implementation of motion planning, path search algorithms, and VIO for autonomous UAV navigation MPC-RL Developing a novel method taht combining RL with MPC for improved sample efficiency fun Remote-Controlled Electric Car Designed and built a remote-controlled electric car from scratch, covering CAD and mechanical design, custom circuits, and the remote-control system. handwritten recognition system Handwritten recognition with HMM slam SLAM with particle filter