Research
-
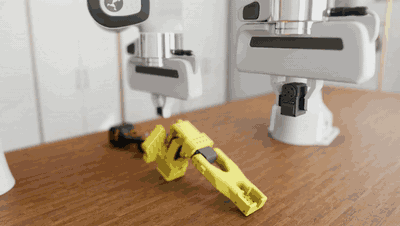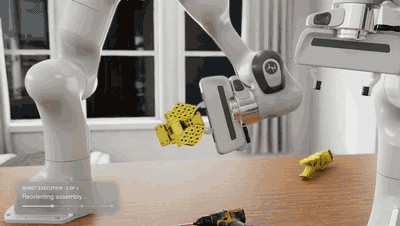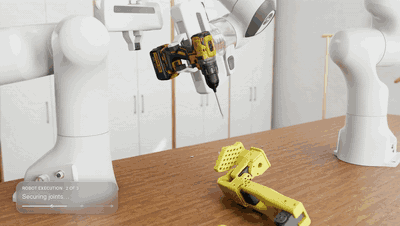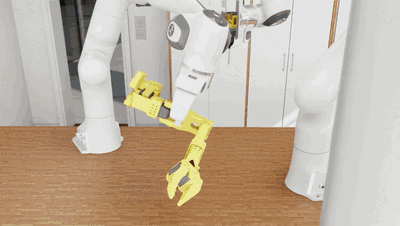 under review 2026We systematically evaluate frontier coding agents on complex, long-horizon everyday robotics tasks, and propose a data-engine pipeline that distills the agents’ capabilities into a local VLA policy deployable on a real robot.
-
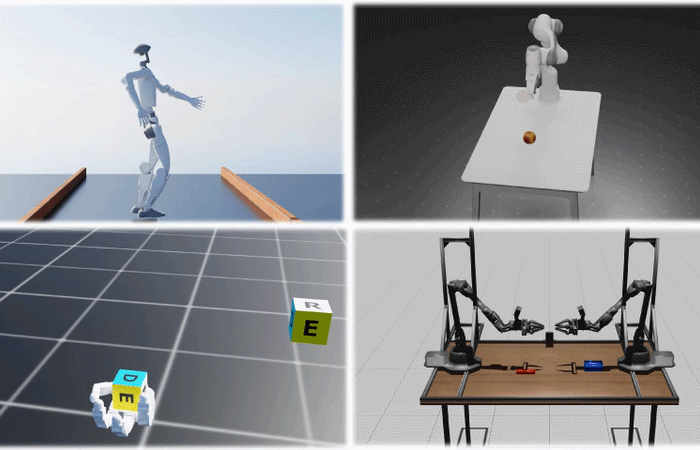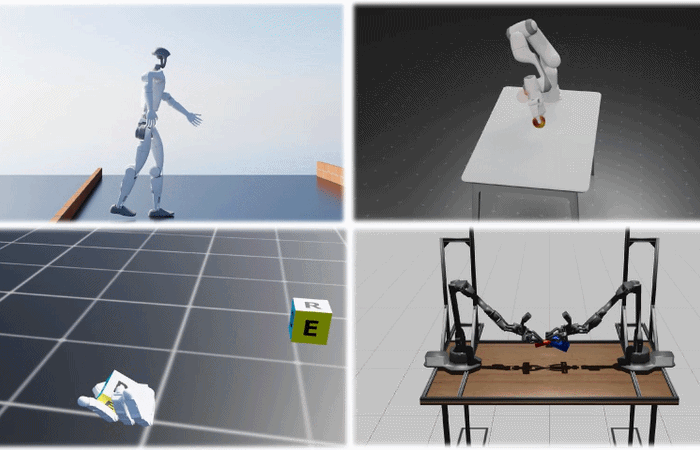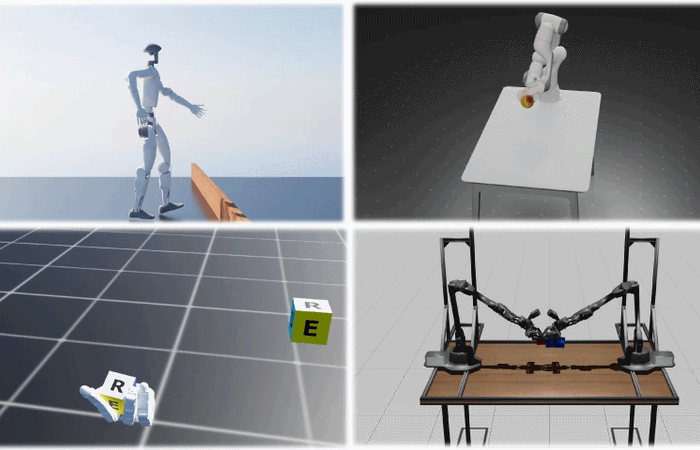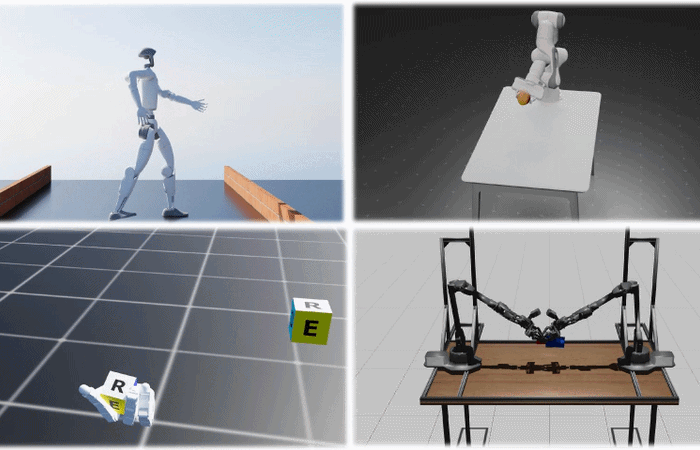 CoRL 2026A lightweight visual RL method that trains visuomotor policies end-to-end within a few hours on a single GPU, with sim-to-real transfer.
-
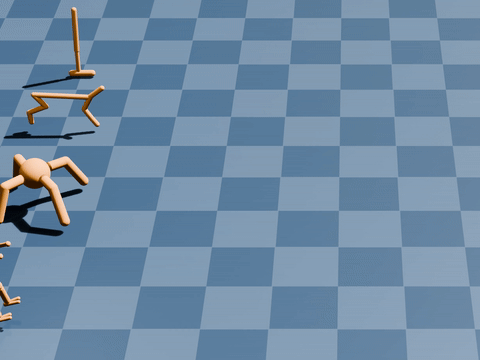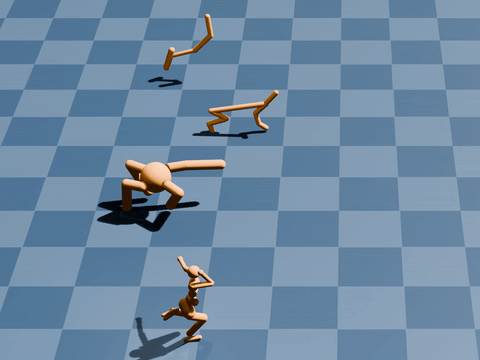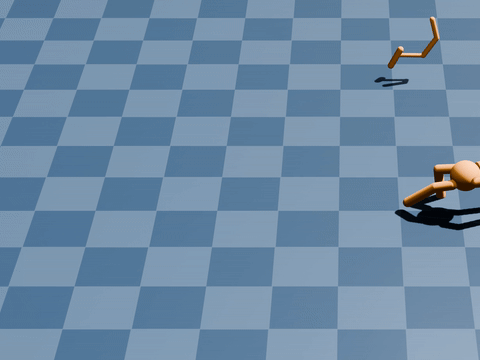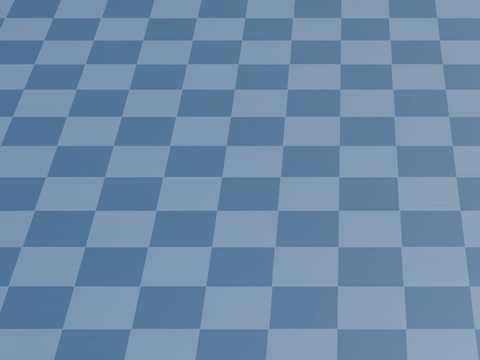 NeurIPS 2025 SpotlightAccelerates visual RL training with differentiable simulation by decoupling rendering from the gradient computation; a humanoid learns to run from raw pixels in 4 hours on a single GPU.
-
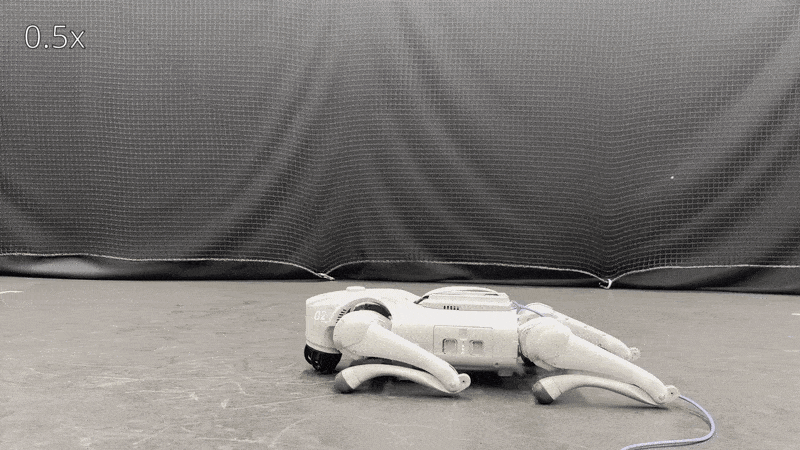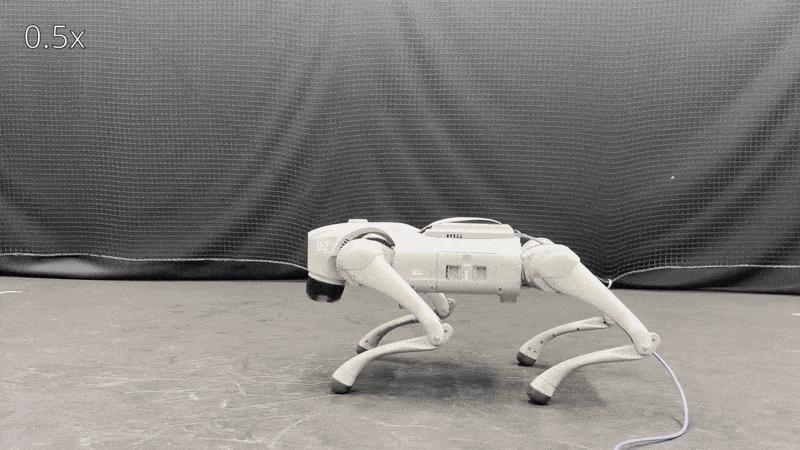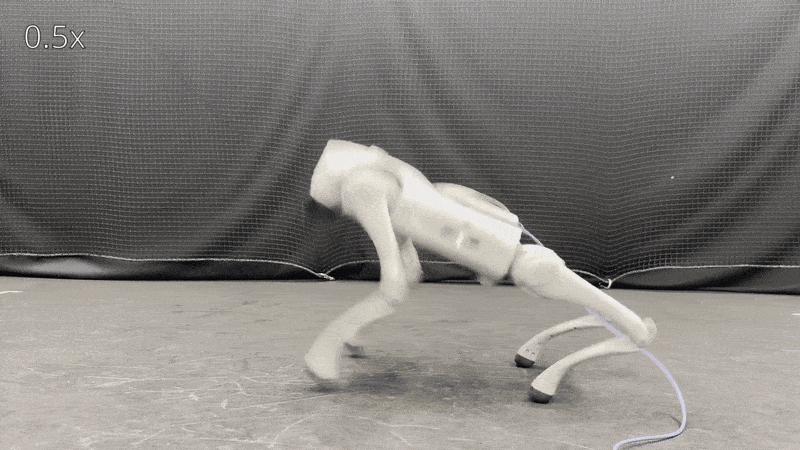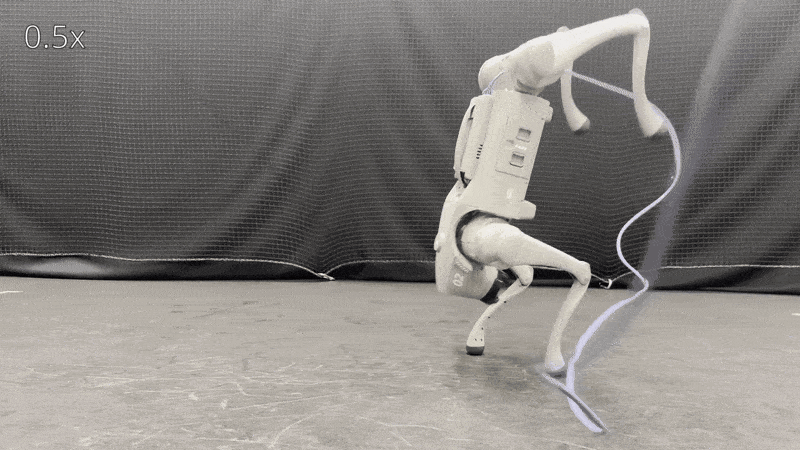 ICRA 2026A sample-based search over different control modes and when to switch between them, enabling agile robot control.
-
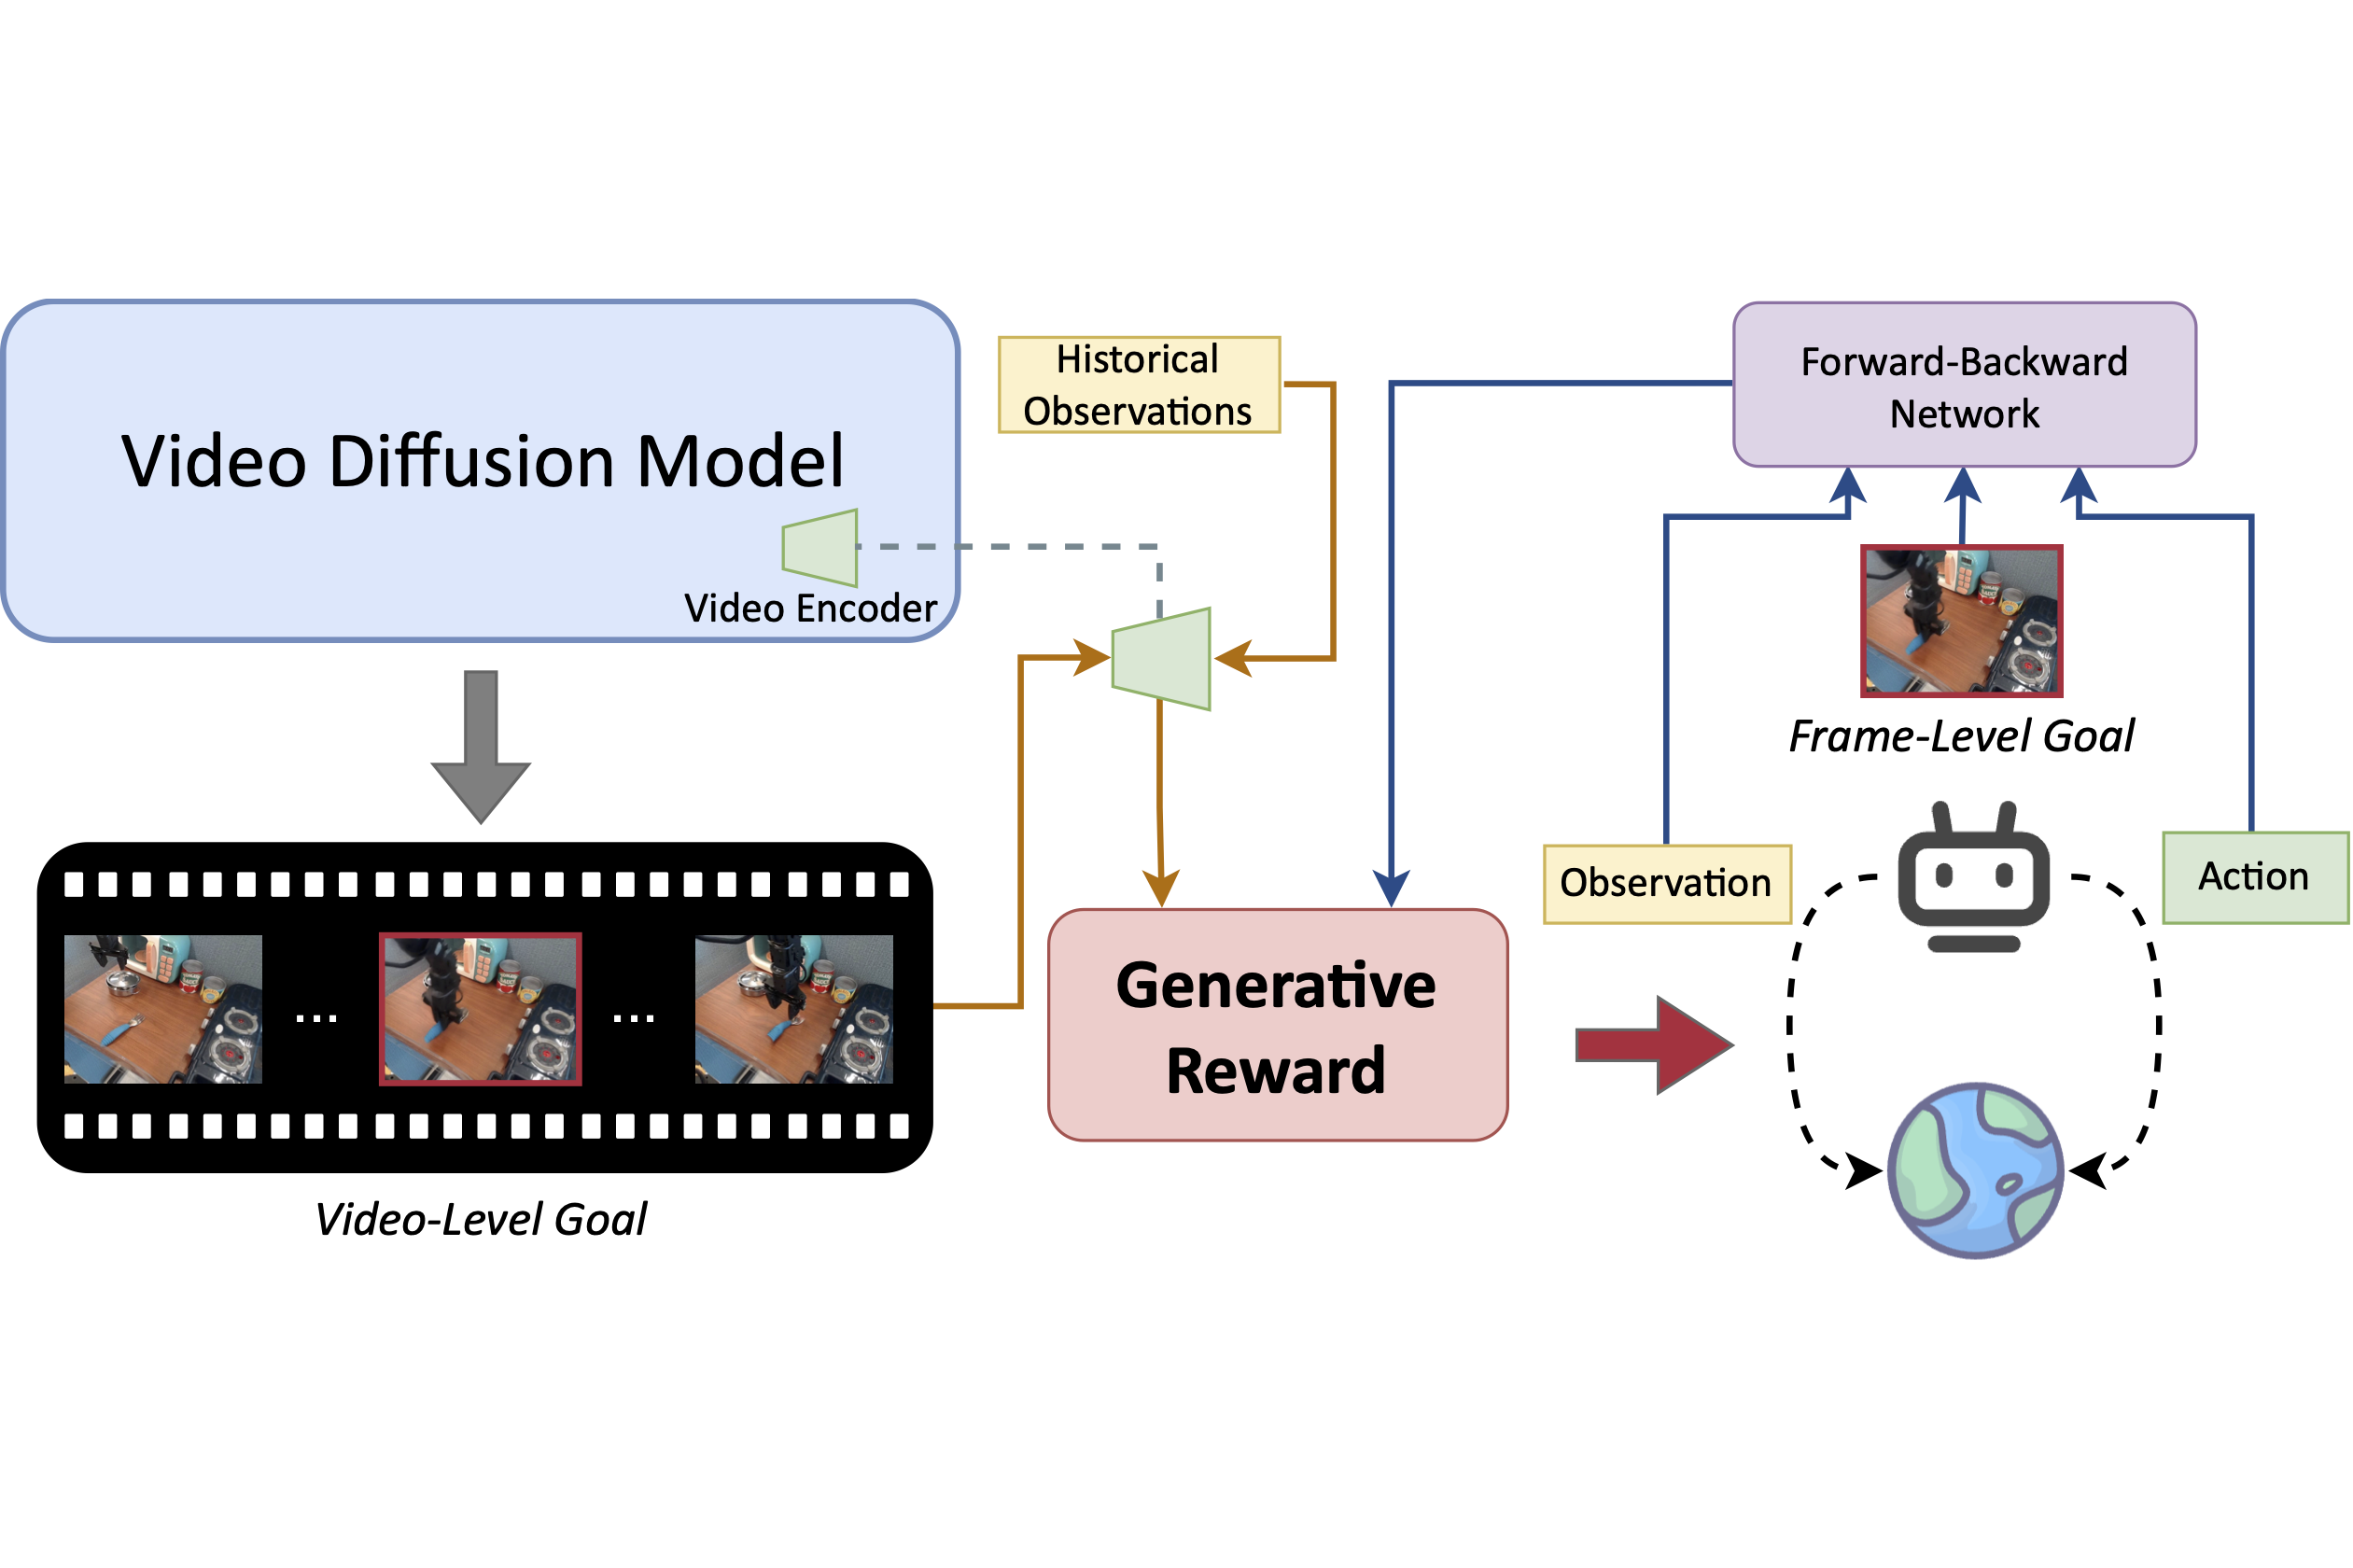 CVPR 2026Replaces hand-designed rewards with pretrained video diffusion models, rewarding agents for following generated goal videos, and even outperforms heavily engineered dense rewards on several manipulation tasks.
-
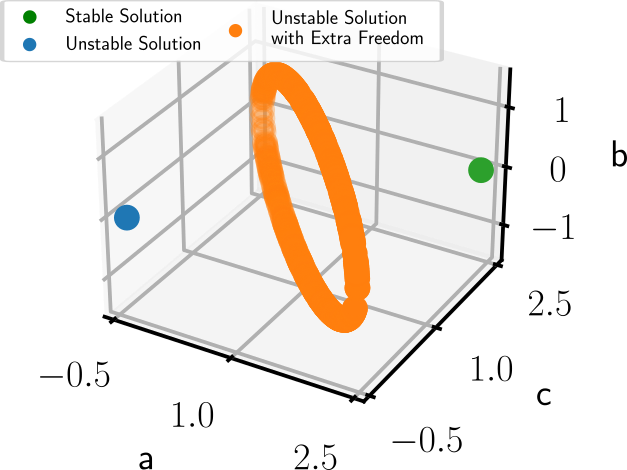 preprint 2025Shows that in continuous state spaces the Bellman equation can have exponentially many solutions, only one of them stable, and proposes a positive-definite network that guarantees converging to it.