Haoxiang You 尤皓翔
I’m a final-year Ph.D. candidate in Mechanical Engineering at Yale University. Previously, I earned my master’s degree from the University of Pennsylvania, and my bachelor’s degree from Ningbo University. Outside the lab, I enjoy DIY projects, cooking, and computer games.
I work on robotics, physical agents, reinforcement learning and simulation. Along the way I have worked across much of the robotics stack, including hardware design, control, data collection, simulation, model training and deployment. More recently, my interests lie in agentic robotics: using AI agents to make robots more capable and robot learning more scalable.
I am on the job market and expect to graduate in 2027. My CV is available here. If you think I could be a good fit for your team, please reach out at haoxiang.you@yale.edu.
News
| [09/2026] | We released “EmbodiedSWE: Coding Agents for Long-Horizon Dexterous Robotics”! Check out the paper, website, and code. 🚀🦾 |
|---|---|
| [09/2026] | Our work “Efficient On-policy Visual-RL via Stochastic Decoupled Policy Gradient” has been accepted to CoRL 2026! 🤖🎉 |
| [02/2026] | Our collabrative work “Goal-Driven Reward by Video Diffusion Models for Reinforcement Learning” has been accepted to CVPR 2026! 🎬✨ |
| [01/2026] | Our work on sample-based hybrid mode control has been accepted to ICRA 2026! 🤖🎉 |
| [09/2025] | Our work “D.Va” has been accepted to NeurIPS 2025 as a Spotlight paper! 🎉✨ |
| [07/2025] | I will join Genesis-AI as a Research Scientist Intern. |
| [08/2023] | I will strike out my Phd journey at Yale University |
| [05/2023] | I was graduated from University of Pennsylvania with Outstanding Academic Award  |
Publications
-
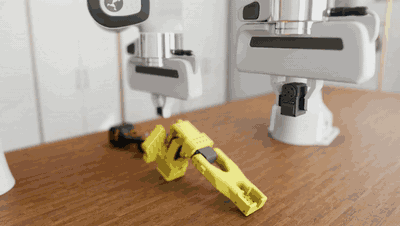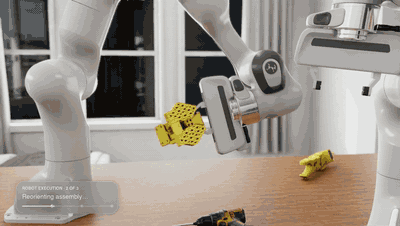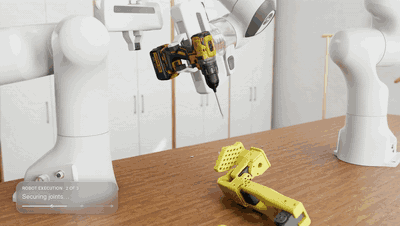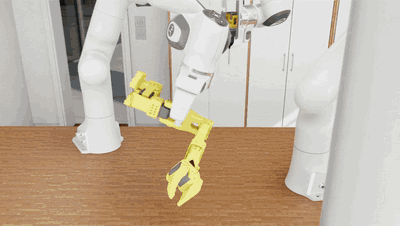 under review 2026We systematically evaluate frontier coding agents on complex, long-horizon everyday robotics tasks, and propose a data-engine pipeline that distills the agents’ capabilities into a local VLA policy deployable on a real robot.
-
 CoRL 2026A lightweight visual RL method that trains visuomotor policies end-to-end within a few hours on a single GPU, with sim-to-real transfer.
-
 NeurIPS 2025 SpotlightAccelerates visual RL training with differentiable simulation by decoupling rendering from the gradient computation; a humanoid learns to run from raw pixels in 4 hours on a single GPU.
-
 ICRA 2026A sample-based search over different control modes and when to switch between them, enabling agile robot control.
-
 CVPR 2026Replaces hand-designed rewards with pretrained video diffusion models, rewarding agents for following generated goal videos, and even outperforms heavily engineered dense rewards on several manipulation tasks.
-
 preprint 2025Shows that in continuous state spaces the Bellman equation can have exponentially many solutions, only one of them stable, and proposes a positive-definite network that guarantees converging to it.
Selected Projects
-
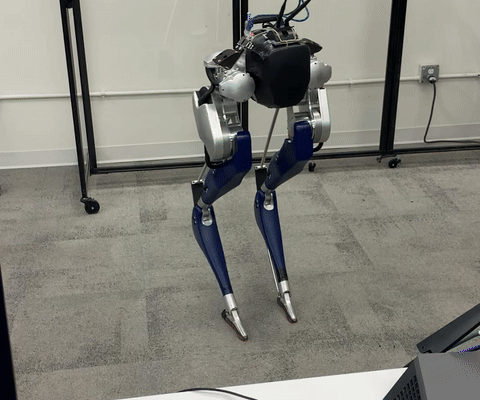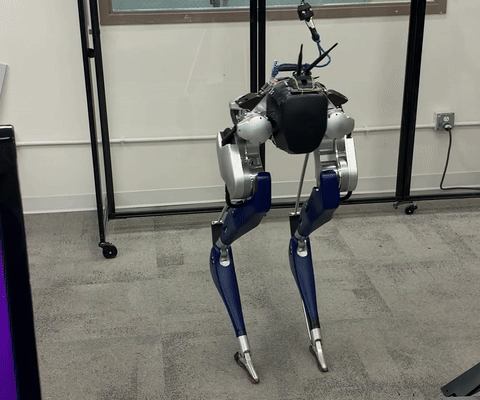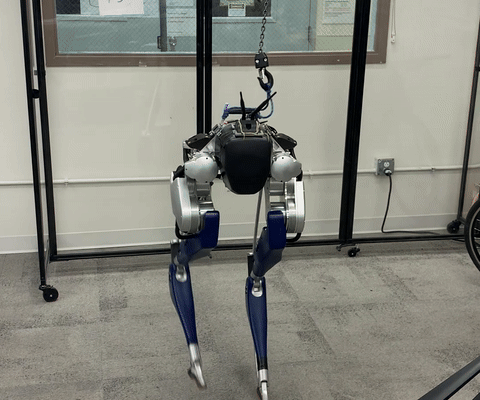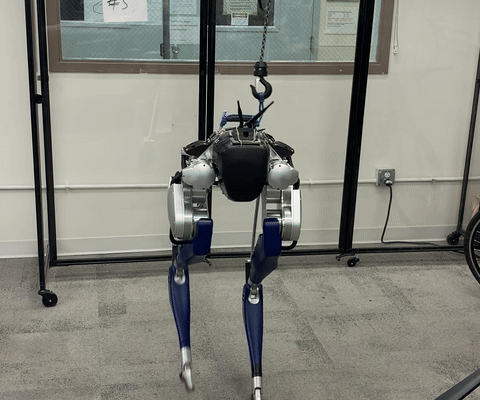 Developed sim-to-real control strategies for the Cassie bipedal robot, focusing on trajectory optimization, feedback control, system identification and state estimation.
-
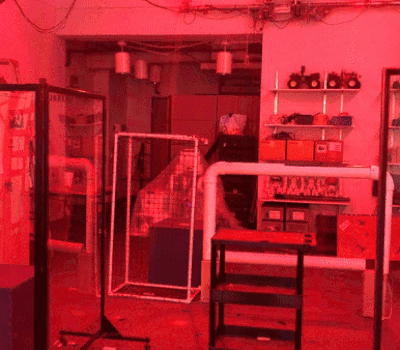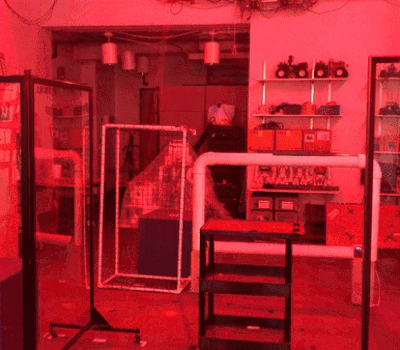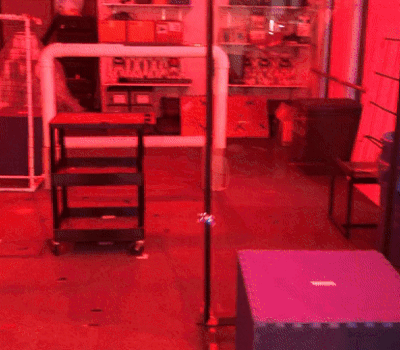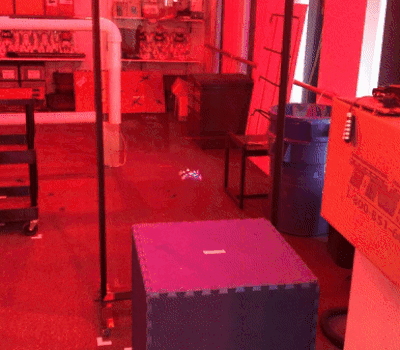 End-to-end implementation of motion planning, path search algorithms, and VIO for autonomous UAV navigation
-
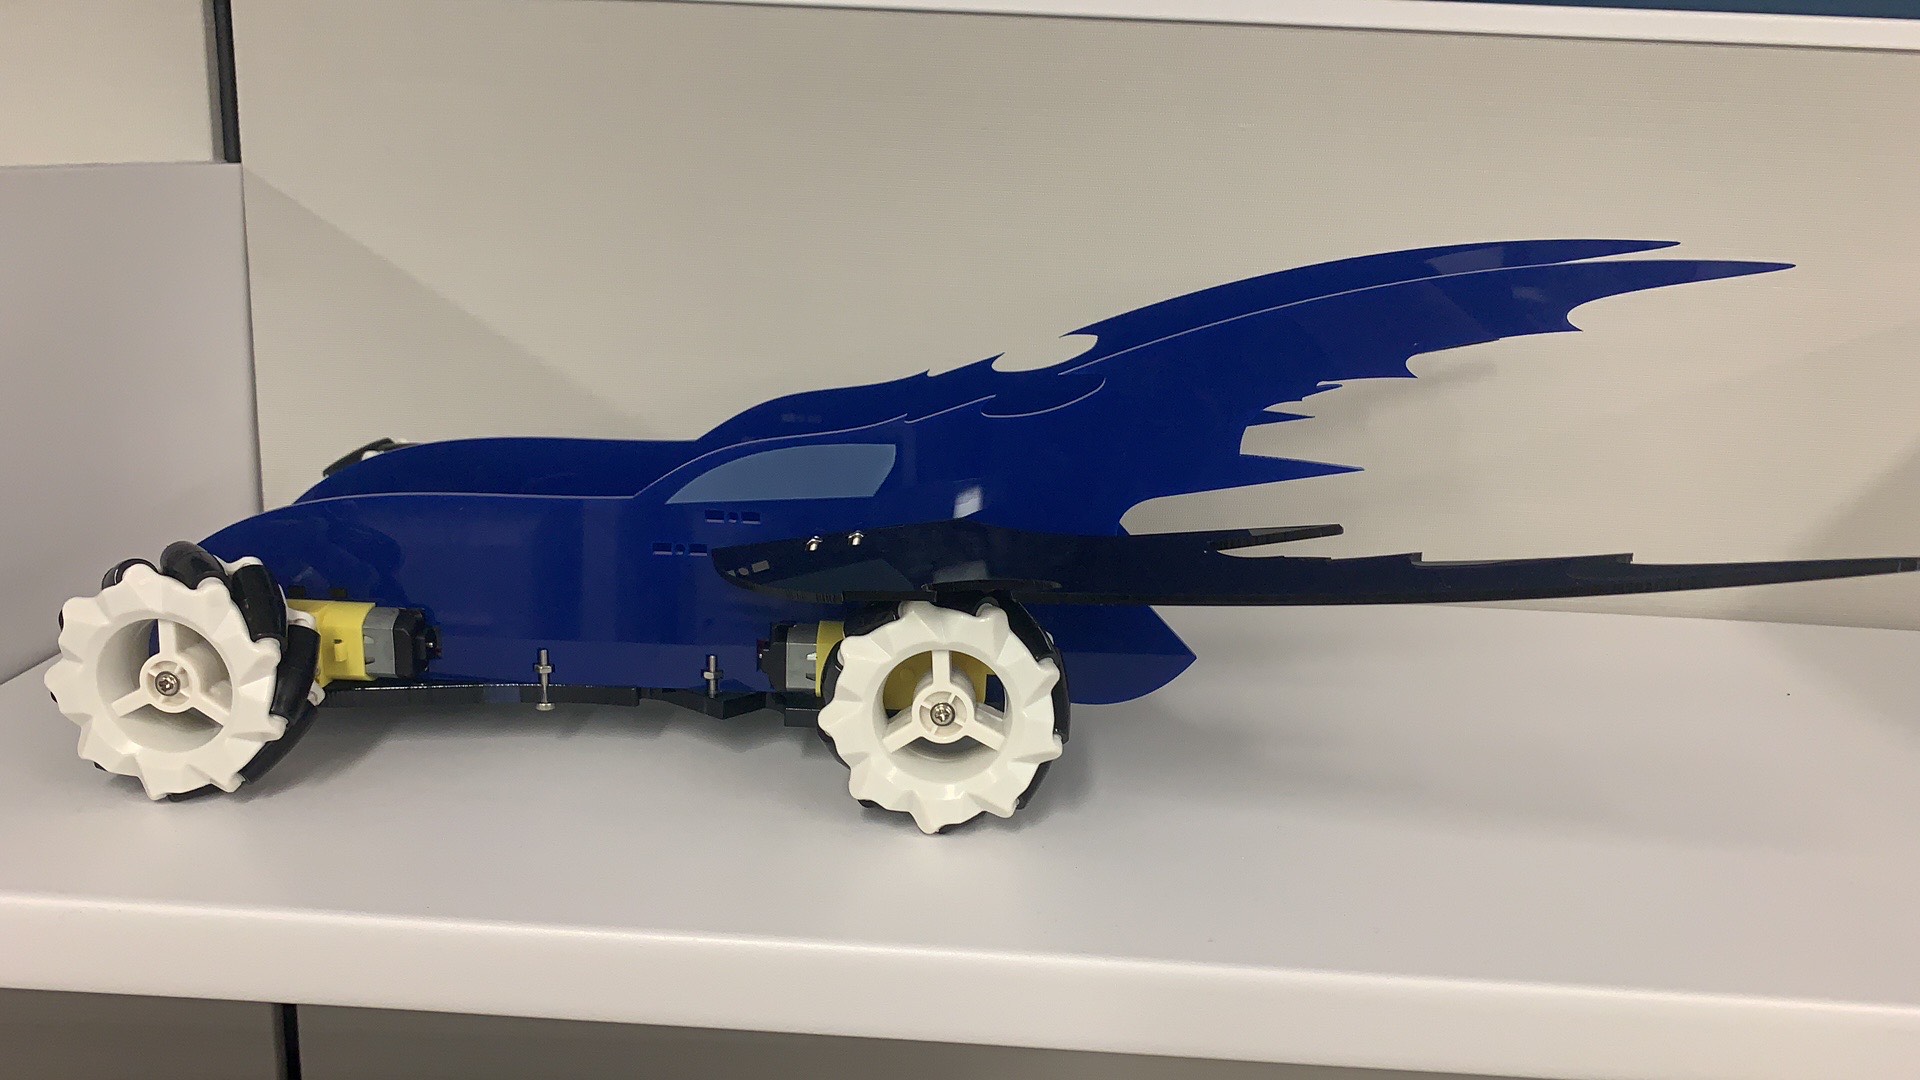 Designed and built a remote-controlled electric car from scratch, covering CAD and mechanical design, custom circuits, and the remote-control system.